Modern Cooperative Autonomous Driving Ecosystem
Introduction: The Problem Is Larger Than the Vehicle
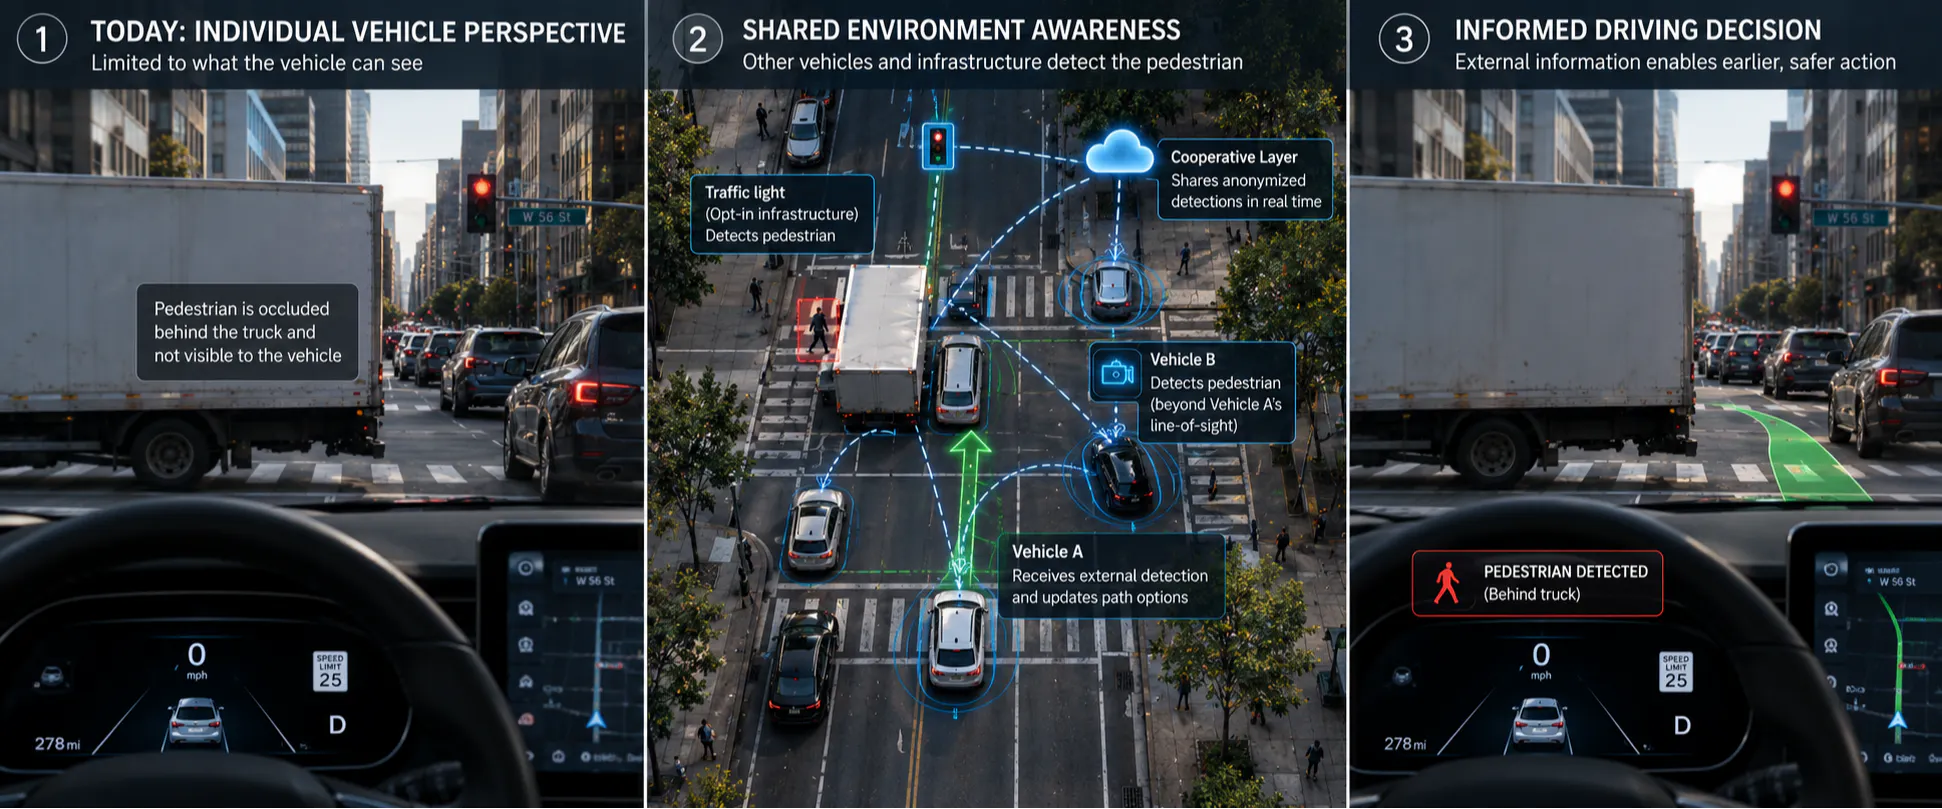
The development of autonomous vehicles has largely focused on making the individual vehicle more intelligent. Better cameras, better radar, better lidar, larger neural networks, better maps, more training data, and increasingly sophisticated systems for interpreting the environment around the vehicle have collectively pushed autonomous driving substantially forward. There is, however, a more fundamental architectural problem that additional compute alone cannot solve: the modern autonomous vehicle is still, for the most part, attempting to understand a shared environment from an individual perspective.
A vehicle observes the world around it, attempts to identify what those observations represent, predicts what the objects it can observe are likely to do, and then determines how it should respond. In many ways, we have recreated the fundamental limitations of a human driver inside a substantially more capable computational system. The machine may have cameras facing in every direction....
Copyright of this story solely belongs to hackernoon.com. To see the full text click HERE