Can Real-Time Drone Detection Run on the Edge?
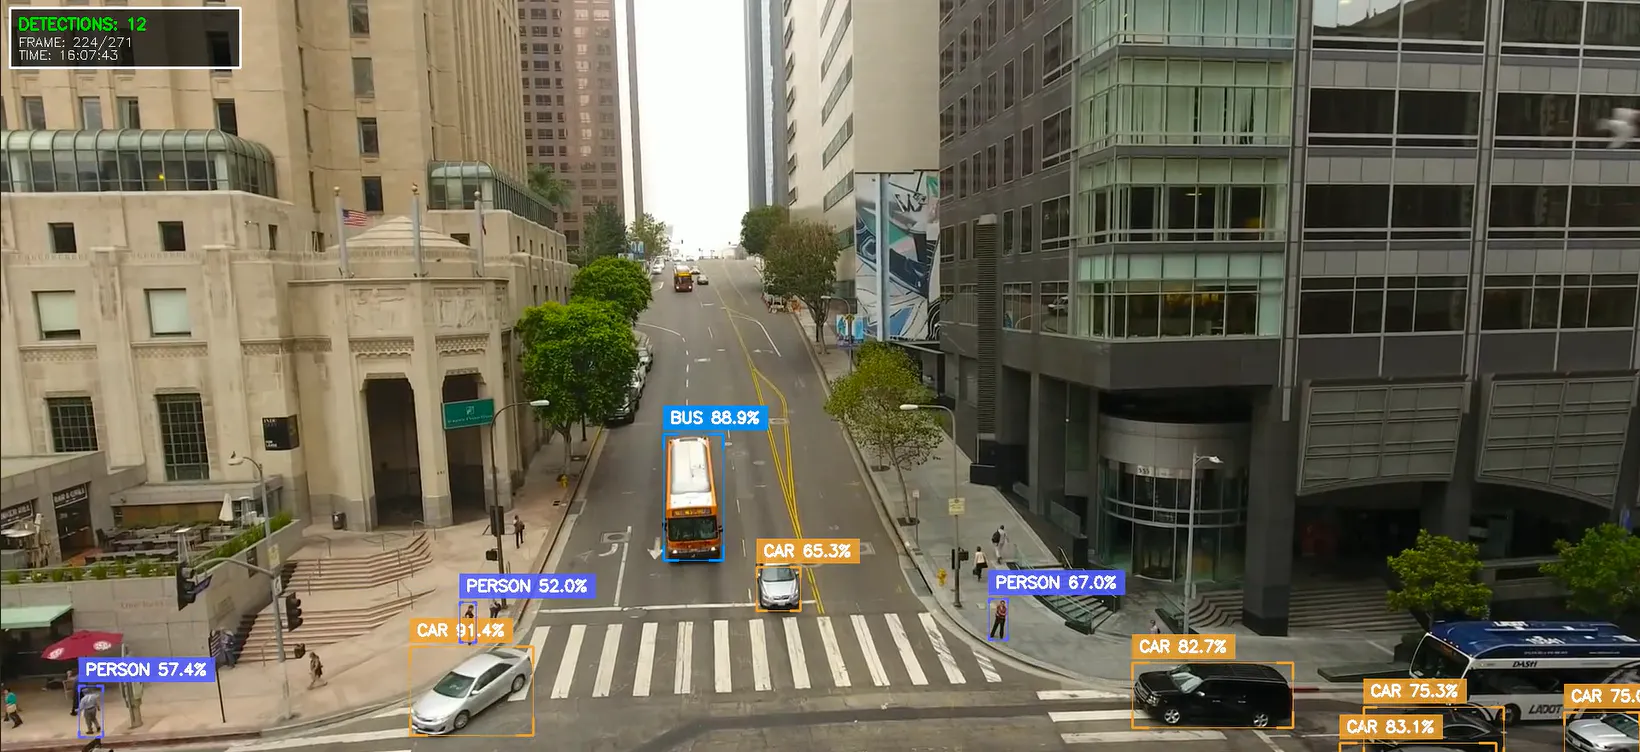
Unmanned aerial vehicles are one of the defining hardware stories of the last decade, and the interesting frontier now isn't the airframe, and it's the intelligence you can cram onto it. Once you start bolting computer vision onto a drone, you hit a wall almost immediately: the models that detect and track objects reliably are hungry, and the compute you can carry on a small aircraft is not. Everything downstream including, vision-driven swarming, collaborative sensor fusion, autonomous target following, that depends on solving that tension between what the model wants and what the battery and the board can give.
That's exactly the tension this paper interrogates. Rather than proposing a new architecture, the authors run a comparative performance analysis of a representative real-time UAV image-processing pipeline across several edge devices. As someone who spends a lot of time on the deployment side of this problem, I find that framing more...
Copyright of this story solely belongs to hackernoon.com. To see the full text click HERE